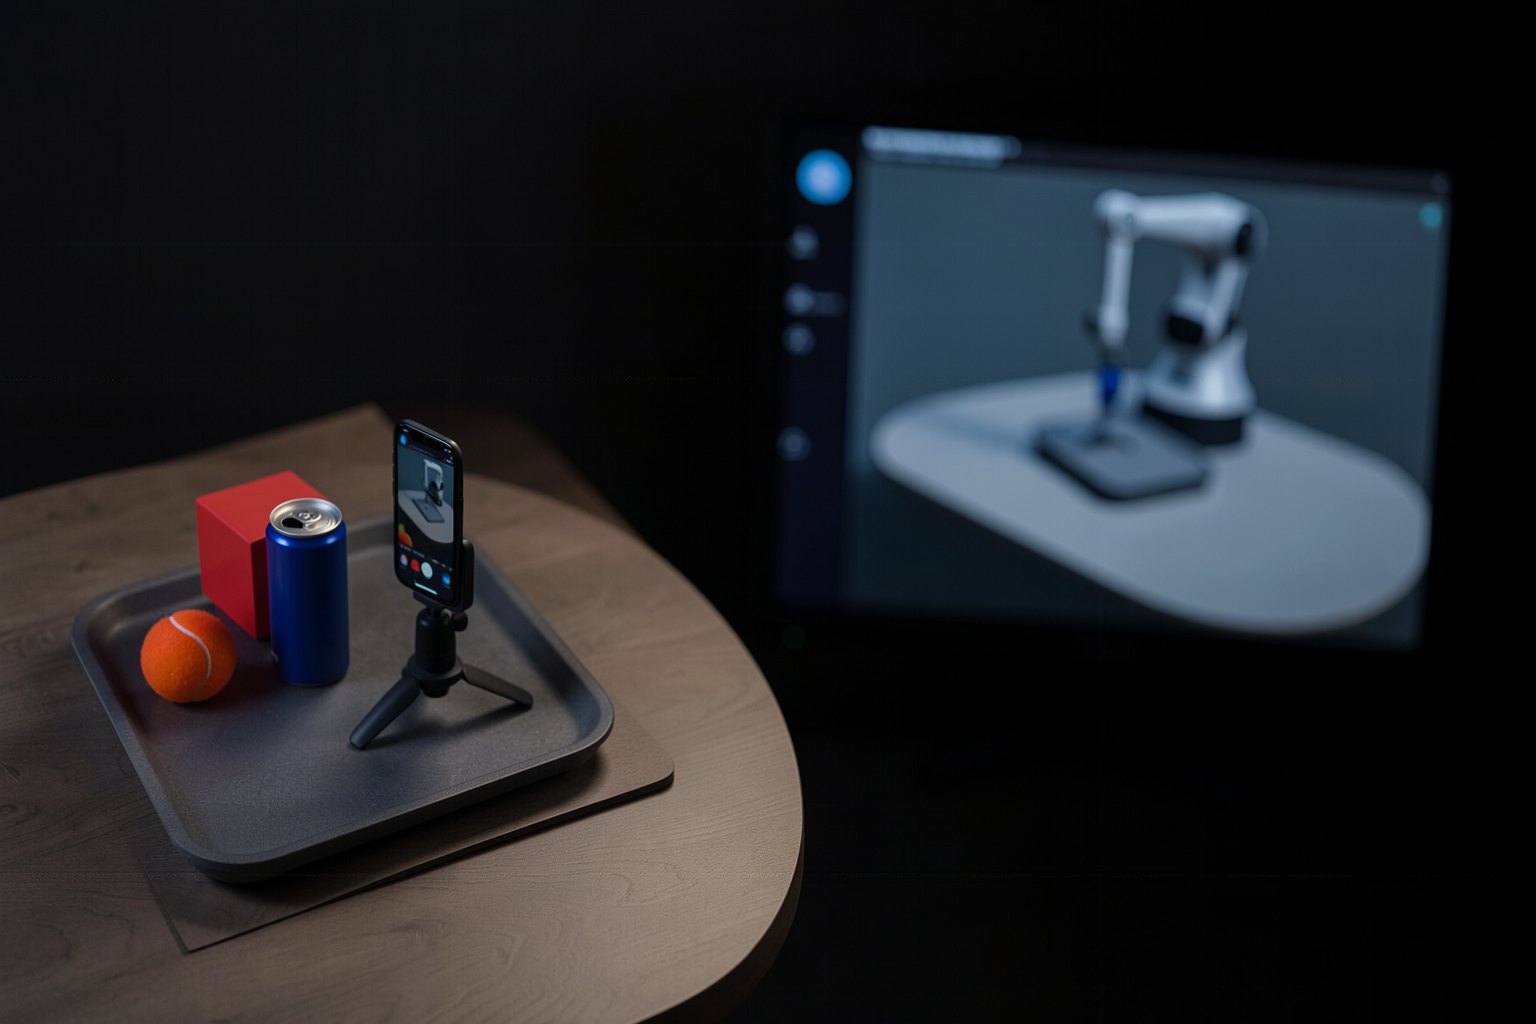
Real-to-sim: bringing the real world into the simulator
So far the path has gone from the simulator to the robot. The reverse path exists too: photograph the real place and build a twin where the robot trains and is tested first. In this lesson you run the twin from the robotica-real2sim project (an arm, not a humanoid) in the course venv and prove a plan in the physics, and you see where this stands for humanoids in 2026.
2The robotica-real2sim twin running with the Menagerie from your bench
3A plan approved in 19 of 20 variations in the physics
4Real-to-sim for humanoids in 2026: vendor demo, reported
Goal: run the robotica-real2sim twin in the course venv and prove a plan in the physics before the robot, counting the objects in the scene.
01 · From the real place to the twin
Click each block. This is the robotica-real2sim flow.
Click each block in the diagram to see what it does.
Real-to-sim is the subject of robotica-real2sim. Here it runs and is tied to the ladder: a twin (digital twin) of the place is one more step before the floor.
02 · What about humanoids?
Status as of Oct 2026, according to the program's research. Click each item.
1. Gaussian splatting
Niantic Spatial, Flexion and NVIDIA showed a scene scanned by camera turning into Gaussian splatting in Isaac Sim, with a humanoid navigation policy trained there and taken to the robot with no tuning. This is vendor material, not a paper with measurements.
2. GaussGym
Berkeley, ETH and Amazon FAR use 3DGS as a renderer inside a vectorized simulator, at 100k+ steps per second (arXiv 2510.15352). Also with no measured sim-to-real on a humanoid as of Oct 2026, according to the research.
3. What is already routine
What already makes it into day-to-day work is simpler: measuring the floor and the friction, weighing the robot, scanning steps and obstacles for the terrain curriculum (course 1).
4. For you
A twin (digital twin) is only as good as the measurement that feeds it. The real2sim project measured this: different vision models got the tray size wrong, and the proof only approves what passes in the worst case.
03 · Run the twin and the proof
Adds the Panda to the bench's Menagerie sparse-checkout, pins robotica-real2sim to the tested commit and points its vendor/menagerie to yours.
Four objects, a 1280×720 image generated by the GPU (EGL), no screen.
plano completo em 19/20 (95%); mínimo 90% -> APROVADO para o robô real
  lata_azul -> bandeja_cinza: 20 ok
  bola_tenis -> bandeja_cinza: 19 ok {'objeto caiu fora do destino': 1}
19 out of 20 (95%): approved. The failure is noted by cause, as in the gate in lesson 6.
                                        ^^^^^^^^^^^^^^^^
AttributeError: 'NoneType' object has no attribute 'glGetError'
r2s.py renders on the GPU (MUJOCO_GL=egl). Without a GPU, switch to osmesa, but the OSMesa library must be installed; without it, you get the error above. Counting objects doesn't depend on rendering: gemeo.py reads cena.json.
04 · The twin (digital twin) in motion
A 10 s clip from robotica-real2sim: one episode with three cameras.
MuJoCo twin of the table: the arm picks up the cube (clip from robotica-real2sim) · 0:10Video page with script →
05 · Practice
The real world inside the simulator.
E1 · Twin (digital twin) rendered
5 min
Run the twin block and open gemeo.png.
Done when:python3 ~/fth/sim2real/kit/gemeo.py exemplos/mesa-foto/cena.json ~/fth/gemeo.png (in the robotica-real2sim folder) → objetos na cena: 4 and gemeo.png: 1280×720 px.
E2 · Proof of the plan
3 min
Prove the example plan in 20 variations.
Done when:python3 r2s.py provar … -n 20 | tail -3 → plano completo em 19/20 (95%); mínimo 90% -> APROVADO para o robô real.
E3 · What you would scan
10 min
For a G1 that will walk down a factory corridor, list three measurements of the real place that you would bring into the simulator before the ladder in lesson 8.
Done when: three items with what to measure and with which instrument (e.g., floor friction with an inclined plane; step height with a tape measure).
06 · Lesson quiz
The explanation appears after your answer.
Question 1 of 3
What does real-to-sim do that sim-to-real does not?skill
Correct
It's the opposite direction: measure the world and build the twin. Then the way back (sim-to-real) still uses randomization, the gate, and the ladder.
Not this one
It's the opposite direction: measure the world and build the twin. Then the way back (sim-to-real) still uses randomization, the gate, and the ladder.Review: From the real place to the twin
Question 2 of 3
As of Oct 2026, real-to-sim with Gaussian splatting for humanoids is:
Correct
The course research found demos (Niantic/Flexion/NVIDIA) and GaussGym, but no published sim-to-real measurement for a humanoid. Stated as reported.
Not this one
The course research found demos (Niantic/Flexion/NVIDIA) and GaussGym, but no published sim-to-real measurement for a humanoid. Stated as reported.Review: What about humanoids?
Question 3 of 3
Without a GPU, r2s.py ver gives an OpenGL error. How do you go on?
Correct
The rendering is just the image. With OSMesa it runs on the CPU; the object count and the physics test don't even need rendering.
Not this one
The rendering is just the image. With OSMesa it runs on the CPU; the object count and the physics test don't even need rendering.Review: Run the twin and the proof
Quiz complete
You got {a} of {n} right. Get them all right and the lesson is marked as done.
Pick one answer. The explanation appears after you try.
07 · In three sentences
FlowPhoto, scene, twin, and a physics test before the robot.
MeasurementThe example plan passes 19 of 20 variations.
HumanoidA splatting twin (digital twin) for humanoids is still a vendor demo (reported); measuring the place is already routine.